
Force and torque
1 parts with data · 52 more listed by name. Columns, units and filters follow this category's display rules. Rows run from small to large. Each cell links through the part page to its source. m marks an independent measurement. How it works
 6 axis strain gauge (1)
| Pick to compare | Maker | Model | Force range Fx, FyN | Force range FzN | Torque range Tx, TyN·m | Torque range TzN·m | Resolution Fx, FyN | Resolution FzN | Resolution Tx, TyN·m | Resolution TzN·m | Massg | Price, 1 pcUSD |
|---|---|---|---|---|---|---|---|---|---|---|---|---|
| Robotiq | FT 300-SFT 300-S | 440 |
How it works
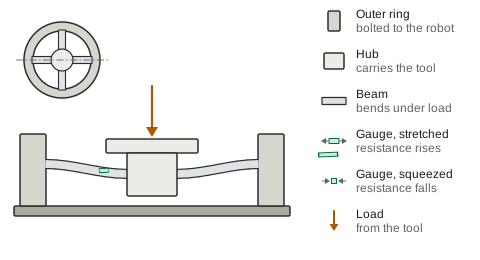
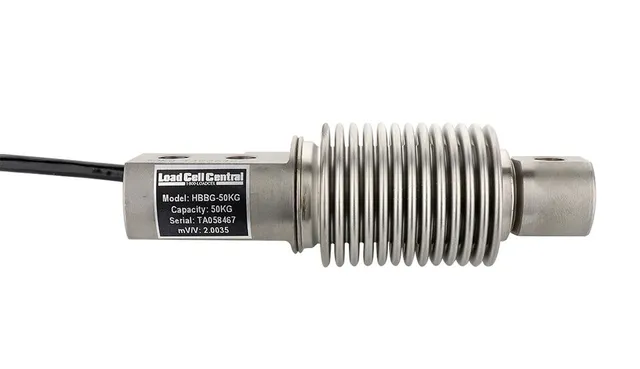
Photo: Daraceleste, CC BY-SA 4.0. source · credits

Types and how they differ
6-axis force/torque sensor: A flexure body with strain gauges or optical/capacitive sensing returns three forces and three torques.
Variations: Silicon strain gauge (ATI Mini40); Strain gauge cobot wrist sensor (Robotiq FT 300-S); Optical (OnRobot HEX); Capacitive-style compact sensor (Bota Rokubi)
For: Direct contact-force feedback for assembly, polishing and compliant control; Ready-made drivers (Modbus, EtherCAT, USB)
Against: Prices not published on the captured vendor pages (quote on request); no public price in this unit; Needs temperature and gravity compensation; Overload can damage the flexure; vendors quote overload multiples
Sources: 1