Robots
278 robots with data · 21 more listed by name
Height, reach, mass and payload in SI units. A value shown with its own unit is as its source states it. Blank means no source was found. Pictures: a pixel-art render of the open 3D model of the robot where one exists, else a free photo, else a pixel drawing of the robot type. Order: most support first: a 3D view, a parts list, open source, model files, a photo, listed specifications.
Build an open robot (25 with a parts list) Robots in 3D · How a robot fits together
Pick a type
Robot types
Serial articulated arm: A chain of rigid links joined by motor-driven joints, ending in a tool or hand. It is the most common industrial robot layout, with 5 to 7 rotary axes in the models catalogued here.
Variations: 6-axis industrial arm; 7-axis redundant arm (extra joint for elbow posture); 5-axis low-cost arm; Desktop research arm
For: Wide reach and reorientation range from one compact base; Many catalogued models, simulation files and ROS drivers exist; A 7th axis lets the elbow move without moving the tool
Against: Joint errors add up along the chain, so stiffness and accuracy fall with reach; Payload falls as reach grows (compare payload and reach of the UR series in the facts file); Singularities limit motion near some poses
Sources: 1, 2
SCARA: Two parallel vertical rotary joints plus a vertical slide: stiff in the vertical axis, slightly compliant in the horizontal plane. Built for assembly and pick and place.
Variations: Standard SCARA; Desktop four-axis arms (for example the Dobot MG400 class)
For: Compliance in X-Y helps insert pins into holes without binding; Can reach into confined spaces and fold away; Rigid vertical axis suits pressing and insertion
Against: Only four degrees of freedom: no tilting of the tool; Works in a plane, so it suits flat assembly more than free-form tasks
Sources: 1
Delta robot: A parallel robot with three arms joined to a small triangular platform; all motors sit in the fixed base, so the moving mass is small.
Variations: 3-axis delta; 4-axis delta with a rotating wrist; Miniature piezo delta (research)
For: Very high speed and acceleration: moving parts have small inertia; Stiff because the three arms connect to the same platform; Common in picking and packaging lines
Against: Small working volume compared with a serial arm; Suits light parts only
Sources: 1, 2
Parallel manipulator (Stewart platform and relatives): Several short actuated chains support one platform. The best known form uses six linear actuators (hexapod).
Variations: Stewart platform / hexapod; Delta (3 translation axes); Lower-mobility parallel robots with fewer than 6 DoF
For: Each chain is short and rigid; positioning errors average instead of adding up; Heavy actuators can sit on the base, so moving mass is low; Good for high-speed, high-accuracy positioning
Against: Limited workspace; Singularities inside the workspace; Nonlinear mapping from command to end-effector motion
Sources: 1, 2
Cartesian / gantry robot: Three linear axes at right angles to each other. Control is simple because each axis maps straight to one coordinate.
Variations: Overhead gantry; Cantilever linear robot; XY table / plotter style
For: Simple kinematics and control; Easy to scale the working volume by lengthening axes; Straight-line motion matches machine tools, 3D printers and plotters
Against: Large frame for a given reach; No tool orientation unless a wrist is added; Moving mass of the stacked axes limits speed
Sources: 1
Collaborative robot (cobot): An arm built to work next to people, with lightweight construction, rounded edges and limits on force and speed. Payload is usually below that of a fenced industrial arm.
Variations: Low-payload cobot (3 to 5 kg); Mid-payload cobot (10 to 15 kg); High-payload cobot (20 to 35 kg, UR20 and UR30 class); Research cobot with joint torque sensing (Franka FR3, Kinova Gen3)
For: Can run without a safety fence when a risk assessment allows it; Hand-guiding and simple teach pendants shorten set-up; Joint torque sensors give contact detection and compliant control
Against: Speed and force limits cut throughput; Payload and reach cost more than for a fenced arm of the same size; Safety rests on the whole cell and tool, not only on the arm
Sources: 1, 2
Humanoid robot: A robot with torso, head, two arms and two legs. The goal is to use human tools and spaces. Catalogued sizes run from 35 cm hobby bipeds to 1.9 m industrial machines.
Variations: Full-size humanoid (Atlas, H1, H2); Mid-size humanoid (G1, R1, Booster T1); Small open-source humanoid (ToddlerBot, OP3, Berkeley Humanoid Lite); Wheeled-base humanoid (Reachy 2 on a mobile base)
For: Fits spaces and tools made for people; Large human demonstration and motion data sets apply directly; Many degrees of freedom (23 to 56 in the catalogued models)
Against: Balance work and falls: runtime is short (Atlas 4 hours); Payload is small for the mass (G1 arms carry about 2 kg); High cost for full-size units and complex maintenance
Sources: 1, 2
Quadruped robot: A four-legged walking robot. Statically stable while standing, so it carries sensors and payloads over stairs and rough ground.
Variations: Consumer / education (Unitree Go2); Industrial inspection (ANYmal, Unitree B2 and A2); Dog with arm (Spot Arm)
For: Four legs give stability and terrain access that wheels lack; Vendor runtime figures range from 90 min (ANYmal) to 4-6 h (Unitree B2); Mounting plates for sensors and arms
Against: Cost and mechanical complexity (12 leg joints); Slow compared with wheels on flat floors; Runtime drops under load (B2 walking time is quoted for 20 kg load separately)
Sources: 1
Mobile manipulator: A robot arm mounted on a mobile platform. The platform extends the workspace and adds degrees of freedom; control is harder because motion couples.
Variations: Telescoping-arm home robot (Stretch); Dual-arm on omni base (XLeRobot, LeKiwi, TIAGo++); Industrial arm on AGV/AMR
For: Large workspace from a small arm; One platform for navigation and manipulation
Against: Base motion and arm motion must be coordinated; Payload is limited by tip-over and arm reach (Stretch 4: 2.5 kg extended); Battery shared between drive and arm
Sources: 1
Wheeled / tracked mobile base: A drive base without arms: differential, omnidirectional or tracked. It carries sensors, computers or arms.
Variations: Differential-drive base (SCOUT MINI); Omnidirectional three-wheel base (LeKiwi); Tracked / skid-steer
For: Cheapest and most energy-efficient way to move on flat floors; Simple control
Against: Cannot climb stairs or step over gaps; Payload and slope rating depend on wheels and motors (SCOUT MINI: 10 kg payload, 1 hour at full load)
Sources: 1
Gripper: The device at the end of an arm that grasps. Four physical classes: impactive (jaws), ingressive (pins), astrictive (suction, magnets) and contiguitive (adhesive).
Variations: Parallel-jaw electric gripper (Robotiq Hand-E); Vacuum / suction; Magnetic; Soft and adaptive fingers
For: Simple and robust; one actuator in many models; Fast cycle time for known parts
Against: Only suits a range of part sizes; Little in-hand manipulation
Sources: 1, 2
Wearable exoskeleton: A device worn on the body that applies force to assist, enable or augment motion. Medical, occupational and recreational uses.
Variations: Rigid powered exoskeleton; Soft exosuit; Passive (spring) exoskeleton for tools or lifting
For: Assists an existing body part instead of replacing it; Can cut worker fatigue or support walking
Against: Must fit and move with the user safely; Battery mass and runtime; Regulation in medical use
Sources: 1
Unmanned aerial vehicle (drone): A flying robot without a pilot on board. Multirotor models in the Menagerie set include the Skydio X2 and Crazyflie 2.
Variations: Multirotor; Fixed-wing; Rotorcraft (helicopter)
For: Fast access over any terrain; Small multirotors are cheap
Against: Short flight time; Little payload; Airspace rules apply
Sources: 1
| Picture | Robot | Maker | Type | Open | DOF | Height (m) | Reach (m) | Mass (kg) | Payload (kg) | Price (USD) | Models | Parts | View |
|---|---|---|---|---|---|---|---|---|---|---|---|---|---|
| SO101 | The Robot Studio | Arm | yes | 0.441 | 0.15 | MJCF, URDF | 28 | 3D | |||||
| XLeRobot | Vector Wang | Mobile manipulator | yes | 0.4 | 12 | 0.6 to 1 | $660 | URDF | 17 | 3D | |||
| G1 | Unitree | Humanoid | yes | 23 to 43 | 1.32 | 35 | 2 to 3 | $13,500 | MJCF, URDF | 3D | |||
| 2XC | ToddlerBot | Humanoid | yes | MJCF, URDF | 93 | 3D | |||||||
| FR3 | Franka Robotics | Arm | yes | 7 | 0.855 | 3 | MJCF, SRDF, URDF | 3D | |||||
| LeKiwi | SIGRobotics UIUC | Mobile manipulator | yes | $482 | URDF | 33 | 3D | ||||||
| Low-cost robot arm | Alexander Koch | Arm | yes | MJCF, URDF | 15 | 3D | |||||||
| 2XM | ToddlerBot | Humanoid | yes | MJCF, URDF | 7 | 3D | |||||||
| Bolt | Open Dynamic Robot Initiative | Biped | yes | SRDF, URDF | 31 | 3D | |||||||
| Go2 | Unitree | Quadruped | yes | 15 | 7 to 10 | $1,600 | MJCF, URDF | 3D | |||||
| Open Duck Mini v2 | Antoine Pirrone | Biped | yes | 0.42 | MJCF | 17 | 3D | ||||||
| Poppy Humanoid | Poppy Project | Humanoid | yes | URDF | 67 | 3D | |||||||
| SO-ARM100 | The Robot Studio | Arm | yes | MJCF, URDF | 12 | 3D | |||||||
| Solo12 | Open Dynamic Robot Initiative | Quadruped | yes | 2.5 | URDF | 5 | 3D | ||||||
| Z1 | Unitree | Arm | yes | 0.74 | 4.3 to 4.5 | 2 to 3 | MJCF, URDF | 3D | |||||
| Amazing Hand | Pollen Robotics | Hand | yes | MJCF | 13 | 3D | |||||||
| Crazyflie 2 | Bitcraze | Drone | yes | 0.027 | 0.015 | MJCF, URDF | 3D | ||||||
| FR3 v2 | Franka Robotics | Arm | yes | 7 | MJCF, SRDF, URDF | 3D | |||||||
| H1 | Unitree | Humanoid | yes | 1.8 | 47 | MJCF, URDF | 3D | ||||||
| UR10e | Universal Robots | Arm | no | 1.3 | 33.5 | 12.5 | MJCF, URDF, Xacro | 3D | |||||
| UR5e | Universal Robots | Arm | no | 0.85 | 20.6 | 5 | MJCF, URDF, Xacro | 3D | |||||
| YAM Ultra v1 | I2RT Robotics | Arm | yes | 6 | 4.52 | MJCF, URDF | 3D | ||||||
| YAM Ultra v2 | I2RT Robotics | Arm | yes | 6 | 4.6 | MJCF, URDF | 3D | ||||||
| 2F-85 | Robotiq | Gripper or end effector | yes | MJCF, URDF, Xacro | 3D | ||||||||
| DACH_TRON2A | LimX Dynamics | Dual arm | yes | MJCF, URDF, Xacro | 3D | ||||||||
| Gen3 | Kinova | Arm | yes | MJCF, URDF, Xacro | 3D | ||||||||
| Koch v1.1 | Jess Moss | Arm | yes | $278 | MJCF, URDF | 21 | |||||||
| Luna | LimX Dynamics | Humanoid | yes | MJCF, SRDF, URDF | 3D | ||||||||
| Oli | LimX Dynamics | Humanoid | yes | MJCF, SRDF, URDF | 3D | ||||||||
| OMY-3M | ROBOTIS | Arm | yes | MJCF, SRDF, URDF | 3D | ||||||||
| PAROL6 | Source Robotics | Arm | yes | 6 | 0.408 | 5.5 | 0.5 to 1 | 62 | |||||
| PF_TRON1A | LimX Dynamics | Biped | yes | MJCF, URDF, Xacro | 3D | ||||||||
| PF_TRON1B | LimX Dynamics | Biped | yes | MJCF, URDF, Xacro | 3D | ||||||||
| Rizon4 | Flexiv Robotics | Arm | yes | MJCF, URDF, Xacro | 3D | ||||||||
| Sawyer | Rethink Robotics | Arm | yes | MJCF, Xacro | 3D | ||||||||
| SF_TRON1A | LimX Dynamics | Biped | yes | MJCF, URDF, Xacro | 3D | ||||||||
| SF_TRON1B | LimX Dynamics | Biped | yes | MJCF, URDF, Xacro | 3D | ||||||||
| SF_TRON2A | LimX Dynamics | Biped | yes | MJCF, URDF, Xacro | 3D | ||||||||
| SFYG_TRON2A | LimX Dynamics | Biped | yes | MJCF, URDF, Xacro | 3D | ||||||||
| Thor | Angel LM | Arm | yes | 6 | 0.625 | 0.75 | 58 | ||||||
| WF_TRON1A | LimX Dynamics | Biped | yes | MJCF, URDF, Xacro | 3D | ||||||||
| WF_TRON1B | LimX Dynamics | Biped | yes | MJCF, URDF, Xacro | 3D | ||||||||
| WF_TRON2A | LimX Dynamics | Biped | yes | MJCF, URDF, Xacro | 3D | ||||||||
| WFYG_TRON2A | LimX Dynamics | Biped | yes | MJCF, URDF, Xacro | 3D | ||||||||
| xArm7 | UFACTORY | Arm | yes | MJCF, SRDF, URDF, Xacro | 3D | ||||||||
| 2F-85 v4 | Robotiq | Gripper or end effector | yes | MJCF, URDF | 3D | ||||||||
| A1 | Unitree | Quadruped | yes | MJCF, URDF | 3D | ||||||||
| Aero Hand | TetherIA | Gripper or end effector | yes | MJCF, URDF | 3D | ||||||||
| Agility Cassie | Agility Robotics | Biped | yes | MJCF, URDF | 3D | ||||||||
| Allegro Hand | Wonik Robotics | Gripper or end effector | yes | MJCF, URDF | 3D | ||||||||
| ANYmal B | ANYbotics | Quadruped | yes | MJCF, URDF | 3D | ||||||||
| ANYmal C | ANYbotics | Quadruped | yes | MJCF, URDF | 3D | ||||||||
| Barkour v0 | Quadruped | yes | MJCF, URDF | 3D | |||||||||
| Barkour vB | Quadruped | yes | MJCF, URDF | 3D | |||||||||
| Berkeley Humanoid | UC Berkeley | Humanoid | yes | MJCF, URDF | 3D | ||||||||
| Big YAM | I2RT Robotics | Arm | yes | MJCF, URDF | 3D | ||||||||
| Elf2 | BXI Robotics | Humanoid | yes | MJCF, URDF | 3D | ||||||||
| Go1 | Unitree | Quadruped | yes | MJCF, URDF | 3D | ||||||||
| Lite 6 | UFACTORY | Arm | yes | MJCF, Xacro | 3D | ||||||||
| N1 | Fourier | Humanoid | yes | MJCF, URDF | 3D | ||||||||
| omnidirectional | Robot Soccer Kit | Wheeled base | yes | MJCF, URDF | 3D | ||||||||
| OMX-F | ROBOTIS | Arm | yes | SRDF, URDF | 3D | ||||||||
| OpenArm v1 | Enactic | Dual arm | yes | MJCF, URDF | 3D | ||||||||
| OpenMANIPULATOR-X | ROBOTIS | Arm | yes | SRDF, URDF | 3D | ||||||||
| PiPER | AgileX | Arm | yes | MJCF, URDF | 3D | ||||||||
| Pupper v3 | Gabrael Levine | Quadruped | yes | MJCF, URDF | 3D | ||||||||
| RBY1 | Rainbow Robotics | Mobile manipulator | yes | MJCF, URDF | 3D | ||||||||
| Solo | ODRI | Quadruped | yes | SRDF, URDF | 3D | ||||||||
| Spot | Boston Dynamics | Quadruped | no | $74,500 | MJCF, Xacro | 3D | |||||||
| Stretch 3 | Hello Robot | Mobile manipulator | yes | MJCF, URDF | 3D | ||||||||
| UR10 | Universal Robots | Arm | yes | 1.3 | 28.9 | 10 | URDF, URDF parameters (YAML), Xacro | ||||||
| UR3 | Universal Robots | Arm | yes | 0.5 | 11 | 3 | URDF, URDF parameters (YAML), Xacro | ||||||
| UR5 | Universal Robots | Arm | yes | 0.85 | 18.4 | 5 | URDF, URDF parameters (YAML), Xacro | ||||||
| Valkyrie | NASA JSC Robotics | Humanoid | yes | 44 | 1.87 | 129 | URDF, Xacro | ||||||
| WL P311D | LimX Dynamics | Quadruped | yes | SRDF, URDF | 3D | ||||||||
| WL P311E | LimX Dynamics | Quadruped | yes | SRDF, URDF | 3D | ||||||||
| X2 | Skydio | Drone | yes | MJCF, URDF | 3D | ||||||||
| YAM | I2RT Robotics | Arm | yes | MJCF, URDF | 3D | ||||||||
| YAM Pro | I2RT Robotics | Arm | yes | MJCF, URDF | 3D | ||||||||
| Adam_lite | PNDbotics | Humanoid | yes | MJCF | 3D | ||||||||
| ALOHA | aloha | Dual arm | yes | MJCF | 3D | ||||||||
| Apollo | Apptronik | Humanoid | yes | MJCF | 3D | ||||||||
| Dynamixel 2R | ROBOTIS | Arm | yes | MJCF | 3D | ||||||||
| Flybody | flybody authors | Other | yes | MJCF | 3D | ||||||||
| Franka Emika Panda | Franka Robotics | Arm | yes | MJCF | 3D | ||||||||
| L5 | ARX | Arm | yes | MJCF | 3D | ||||||||
| LBR iiwa 14 | KUKA | Arm | yes | MJCF | 3D | ||||||||
| Leap Hand | Carnegie Mellon University | Gripper or end effector | yes | MJCF | 3D | ||||||||
| MS-Human-700 | MS-Human-700 authors | Other | yes | MJCF | 3D | ||||||||
| ODRI Actuator Module v1 | Open Dynamic Robot Initiative | Other | yes | 0.15 | 34 | ||||||||
| ODRI Biped Leg 3DOF v1 | Open Dynamic Robot Initiative | Other | yes | 3 | 0.54 | 27 | |||||||
| OMX-L | ROBOTIS | Arm | yes | URDF | 3D | ||||||||
| OMY-L100 | ROBOTIS | Arm | yes | URDF | 3D | ||||||||
| OP3 | ROBOTIS | Humanoid | yes | MJCF | 3D | ||||||||
| OpenArm | Enactic | Dual arm | yes | MJCF | 3D | ||||||||
| Realsense D435i | Intel | Other | yes | MJCF | 3D | ||||||||
| reBot DevArm | Seeed Studio | Arm | yes | MJCF | 3D | ||||||||
| Rizon4S | Flexiv Robotics | Arm | yes | MJCF | 3D | ||||||||
| Robot | Mobile manipulator | yes | MJCF | 3D | |||||||||
| Shadow DEX-EE | The Shadow Robot Company | Gripper or end effector | yes | MJCF | 3D | ||||||||
| Shadow Hand E3M5 | Shadow Robot | Gripper or end effector | yes | MJCF | 3D | ||||||||
| SO-ARM101 Parallel Gripper | Robonine | Gripper or end effector | yes | 1 | 0.109 | 0.17 | URDF, Xacro | ||||||
| SO-ARM102 | Robonine | Arm | yes | 5 | 0.483 | 0.3 | URDF, Xacro | ||||||
| SoftFoot | IIT | Other | yes | MJCF | 3D | ||||||||
| Stretch 2 | Hello Robot | Mobile manipulator | yes | MJCF | 3D | ||||||||
| TALOS | PAL Robotics | Humanoid | yes | 1.75 | 95 | MJCF, SRDF, URDF, Xacro | |||||||
| TIAGo | PAL Robotics | Mobile manipulator | yes | 110-145 cm | 3 | MJCF, URDF, Xacro | |||||||
| Tidybot | Stanford | Mobile manipulator | yes | MJCF | 3D | ||||||||
| Trossen WXAI | Trossen Robotics | Arm | yes | MJCF | 3D | ||||||||
| UMI-Gripper | UMI | Gripper or end effector | yes | MJCF | 3D | ||||||||
| UR3e | Universal Robots | Arm | yes | 0.5 | 11.2 | 3 | URDF, Xacro | ||||||
| Wave | Sharpa | Gripper or end effector | yes | MJCF | 3D | ||||||||
| WidowX 250 6DOF | Trossen Robotics | Arm | yes | MJCF | 3D | ||||||||
| WidowX AI | Trossen Robotics | Arm | yes | 6 | 0.769 | 4 | 1.5 | URDF | |||||
| BCN3D Moveo | BCN3D Technologies | Arm | yes | 5 | 92 | ||||||||
| Booster T1 | Booster Robotics | Humanoid | unknown | MJCF, URDF | 3D | ||||||||
| H1_2 | Unitree | Humanoid | yes | 27 | 70 | MJCF, URDF | |||||||
| Open Source Rover | NASA JPL | Wheeled base | yes | 109 | |||||||||
| OpenBot | Intel Intelligent Systems Lab | Wheeled base | yes | 16 | |||||||||
| Sesame | Dorian Borian | Quadruped | yes | 8 | 25 | ||||||||
| Stanford Doggo | Stanford Student Robotics | Quadruped | yes | 43 | |||||||||
| UR16e | Universal Robots | Arm | yes | 0.9 | 33.1 | 16 | URDF | ||||||
| UR20 | Universal Robots | Arm | yes | 1.75 | 64 | 20 | URDF parameters (YAML) | ||||||
| UR30 | Universal Robots | Arm | yes | 1.3 | 64 | 30 | URDF parameters (YAML) | ||||||
| B2 | Unitree | Quadruped | yes | 60 | 120 | URDF | |||||||
| FER | Franka Robotics | Arm | yes | MJCF, SRDF, URDF, Xacro | |||||||||
| FR3 v2.1 | Franka Robotics | Arm | yes | 7 | SRDF, URDF | ||||||||
| H2 | Unitree | Humanoid | no | 31 | 1.82 | 70 | $29,900 | URDF | |||||
| Ingenuity | NASA JPL | Drone | yes | 1.8 | URDF | ||||||||
| Jaco2 j2n6s300 | Kinova | Arm | yes | 6 | SRDF, URDF | ||||||||
| Jaco2 j2s6s300 | Kinova | Arm | yes | 6 | SRDF, URDF | ||||||||
| Jaco2 j2s7s300 | Kinova | Arm | yes | 7 | SRDF, URDF | ||||||||
| JAXON | JSK | Humanoid | yes | COLLADA, URDF, VRML | |||||||||
| LeKiwi (Dynamixel version) | SIGRobotics UIUC | Mobile manipulator | yes | 37 | |||||||||
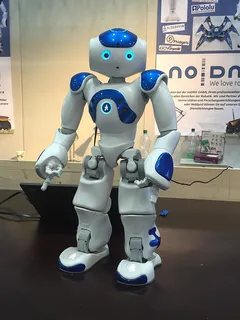
| NAO | SoftBank Robotics | Humanoid | yes | URDF, Xacro | |||||||||
| ODRI Dual Motor Testbed v1 | Open Dynamic Robot Initiative | Other | yes | 25 | |||||||||
| Perseverance | NASA JPL | Mobile manipulator | yes | 2.2 | 1,025 | URDF | |||||||
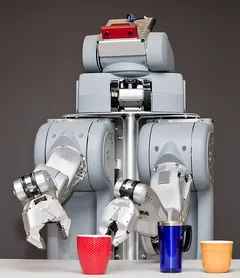
| PR2 | Willow Garage | Dual arm | yes | URDF, Xacro | |||||||||
| R1 | Unitree | Humanoid | no | 26 | 1.23 | 29 | $5,900 | URDF | |||||
| Reachy Mini | Pollen Robotics | Educational or desktop | yes | 1.48 | MJCF, URDF | ||||||||
| Reachy Mini Lite | Pollen Robotics | Educational or desktop | yes | 1.35 | MJCF, URDF | ||||||||
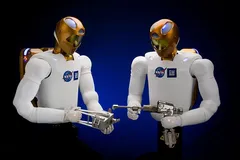
| Robonaut 2 | NASA JSC Robotics | Humanoid | yes | 18 | URDF | ||||||||
| Roboto Origin (ATOM 01) | Roboparty | Humanoid | yes | 62 | |||||||||
| ViperX-300 6DOF | Trossen Robotics | Arm | partial | MJCF | 3D | ||||||||
| xArm6 | UFACTORY | Arm | yes | SRDF, URDF, Xacro | |||||||||
| Ability Hand | PSYONIC, Inc. | Gripper or end effector | yes | MJCF, URDF | |||||||||
| Aliengo | Unitree | Quadruped | yes | MJCF, URDF | |||||||||
| Baxter | Rethink Robotics | Dual arm | yes | URDF, Xacro | |||||||||
| Crazyflie 1.0 | Bitcraze | Drone | yes | 0.019 | Xacro | ||||||||
| CRX-5iA | FANUC | Arm | yes | MJCF, Xacro | |||||||||
| Dual iiwa 14 | KUKA | Dual arm | yes | URDF, Xacro | |||||||||
| FingerEdu | unknown | Educational or desktop | yes | SRDF, URDF | |||||||||
| Gen2 | Kinova | Arm | yes | SRDF, URDF | |||||||||
| Gen3 Lite | Kinova | Arm | yes | SRDF, URDF | |||||||||
| HyQ | IIT | Quadruped | yes | SRDF, URDF | |||||||||
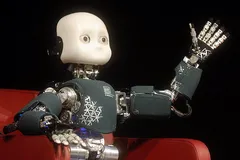
| iCub | IIT | Humanoid | yes | URDF | |||||||||
| iiwa 14 | KUKA | Arm | yes | MJCF, URDF | |||||||||
| Jaco2 j2n4s300 | Kinova | Arm | yes | 4 | URDF | ||||||||
| Jaco2 j2n6s200 | Kinova | Arm | yes | 6 | URDF | ||||||||
| Jaco2 j2n7s300 | Kinova | Arm | yes | 7 | URDF | ||||||||
| Jaco2 j2s6s200 | Kinova | Arm | yes | 6 | URDF | ||||||||
| JVRC-1 | AIST | Humanoid | yes | MJCF, URDF | |||||||||
| Laikago | Unitree | Quadruped | yes | MJCF, URDF | |||||||||
| M-710iC | Fanuc | Arm | yes | URDF, Xacro | |||||||||
| Microban | Rhoban | Humanoid | yes | MJCF, URDF | |||||||||
| Mini Cheetah | MIT | Quadruped | yes | 9.07 | URDF | ||||||||
| NEXTAGE | Kawada Robotics | Dual arm | yes | SRDF, URDF | |||||||||
| OMY-F3M | ROBOTIS | Arm | yes | SRDF, URDF | |||||||||
| Pepper | SoftBank Robotics | Mobile manipulator | yes | URDF | |||||||||
| R1 AIR | Unitree | Humanoid | no | 20 | 27 | $4,900 | URDF | ||||||
| R1 Pro | Galaxea AI | Dual arm | yes | SRDF, URDF | |||||||||
| Simple Humanoid | unknown | Educational or desktop | yes | SRDF, URDF | |||||||||
| ViperX 300 | Trossen Robotics | Arm | yes | MJCF, Xacro | |||||||||
| A2 | Unitree | Quadruped | no | 12 | 42 | URDF | |||||||
| ANYmal D | ANYbotics | Quadruped | yes | URDF | |||||||||
| As2 | Unitree | Quadruped | no | 12 | 20 | URDF | |||||||
| Atlas DRC (v3) | Boston Dynamics | Humanoid | yes | URDF | |||||||||
| Atlas v4 | Boston Dynamics | Humanoid | yes | URDF | |||||||||
| B1 | Unitree | Quadruped | yes | URDF | |||||||||
| BamBot | Tim Qian | Mobile manipulator | yes | URDF | |||||||||
| BarrettHand | Barrett Technology | Gripper or end effector | yes | URDF | |||||||||
| Berkeley Humanoid Lite | UC Berkeley | Humanoid | yes | URDF | |||||||||
| Boxer | Clearpath Robotics | Wheeled base | yes | Xacro | |||||||||
| Cookie | Upkie Project | Biped | yes | URDF | |||||||||
| Dagana Gripper | IIT - HHCM | Gripper or end effector | yes | Xacro | |||||||||
| Dex3-1 | Unitree | Hand | no | 7 | 0.71 | 0.5 | |||||||
| Dingo | Clearpath Robotics | Wheeled base | yes | Xacro | |||||||||
| Double Pendulum | unknown | Educational or desktop | yes | URDF | |||||||||
| Draco3 | Apptronik | Humanoid | yes | URDF | |||||||||
| e.DO | Comau | Arm | yes | URDF | |||||||||
| EGP | SCHUNK | Gripper or end effector | yes | Xacro | |||||||||
| EGU 50 | SCHUNK | Gripper or end effector | yes | Xacro | |||||||||
| Enlight-L | Flexiv Robotics | Arm | yes | URDF | |||||||||
| ergoCub | IIT | Humanoid | yes | URDF | |||||||||
| Eve R3 | Halodi | Mobile manipulator | yes | URDF | |||||||||
| Fetch | Fetch Robotics | Mobile manipulator | yes | URDF | |||||||||
| Ginger | Paaila Technology | Mobile manipulator | yes | URDF | |||||||||
| GR-1 | Fourier | Humanoid | yes | URDF | |||||||||
| Gundam RX-78 | Bandai Namco Filmworks | Humanoid | yes | 18 | |||||||||
| HSR-B | Toyota Motor Corporation | Mobile manipulator | yes | URDF | |||||||||
| HSR-C | Toyota Motor Corporation | Mobile manipulator | yes | URDF | |||||||||
| Husky | Clearpath Robotics | Wheeled base | yes | Xacro | |||||||||
| iiwa 7 | KUKA | Arm | yes | URDF | |||||||||
| Koch v1.1 leader arm | Alexander Koch | Arm | yes | $199 | |||||||||
| LEAP Hand v1 | Carnegie Mellon University | Gripper or end effector | yes | URDF | |||||||||
| LeKiwi 5V version | SIGRobotics UIUC | Mobile manipulator | yes | $499 | |||||||||
| Med 14 | KUKA | Arm | yes | Xacro | |||||||||
| Med 7 | KUKA | Arm | yes | Xacro | |||||||||
| MICO-Core | Flexiv Robotics | Dual arm | yes | URDF | |||||||||
| Minitaur | Ghost Robotics | Quadruped | yes | URDF | |||||||||
| MuJoCo Humanoid | unknown | Educational or desktop | yes | MJCF | |||||||||
| Open Duck Mini | Antoine Pirrone | Biped | yes | 0.35 | |||||||||
| OpenArm v2 | Enactic | Dual arm | yes | URDF | |||||||||
| Panda Gripper | Franka Robotics | Gripper or end effector | yes | MJCF | |||||||||
| Poppy Ergo Jr | Poppy Project | Arm | yes | URDF | |||||||||
| Poppy Torso | Poppy Project | Dual arm | yes | URDF | |||||||||
| PZN-plus | SCHUNK | Gripper or end effector | yes | Xacro | |||||||||
| PZV 64 | SCHUNK | Gripper or end effector | yes | Xacro | |||||||||
| RB-KAIROS+ | Robotnik Automation | Mobile manipulator | yes | Xacro | |||||||||
| RB-ROBOUT+ | Robotnik Automation | Mobile manipulator | yes | Xacro | |||||||||
| RB-SUMMIT | Robotnik Automation | Wheeled base | yes | Xacro | |||||||||
| RB-THERON | Robotnik Automation | Wheeled base | yes | Xacro | |||||||||
| RB-VOGUI+ | Robotnik Automation | Mobile manipulator | yes | Xacro | |||||||||
| Reachy | Pollen Robotics | Mobile manipulator | yes | URDF | |||||||||
| Reachy 2 | Pollen Robotics | Humanoid | yes | Xacro | |||||||||
| Rhea | Gabrael Levine | Biped | yes | URDF | |||||||||
| Ridgeback | Clearpath Robotics | Mobile manipulator | yes | Xacro | |||||||||
| Rizon10 | Flexiv Robotics | Arm | yes | URDF | |||||||||
| Romeo | Aldebaran Robotics | Humanoid | yes | URDF | |||||||||
| Shadow Hand | The Shadow Robot Company | Gripper or end effector | yes | MJCF | |||||||||
| SigmaBan | Rhoban | Humanoid | yes | URDF | |||||||||
| Spryped | Benjamin Bokser | Biped | yes | URDF | |||||||||
| Stretch RE1 | Hello Robot | Mobile manipulator | yes | URDF | |||||||||
| SVH Hand | SCHUNK | Gripper or end effector | yes | Xacro | |||||||||
| ToddlerBot | Stanford University | Humanoid | yes | URDF | |||||||||
| TriFingerEdu | unknown | Educational or desktop | yes | URDF | |||||||||
| Upkie | Upkie Project | Biped | yes | URDF | |||||||||
| UR12e | Universal Robots | Arm | yes | URDF | |||||||||
| UR15 | Universal Robots | Arm | yes | URDF parameters (YAML) | |||||||||
| UR18 | Universal Robots | Arm | yes | URDF parameters (YAML) | |||||||||
| UR7e | Universal Robots | Arm | yes | URDF | |||||||||
| UR8 Long | Universal Robots | Arm | yes | URDF parameters (YAML) | |||||||||
| ViperX | Trossen Robotics | Arm | yes | MJCF | |||||||||
| WALK-MAN | IIT | Humanoid | yes | Xacro | |||||||||
| WidowX | Trossen Robotics | Arm | yes | MJCF | |||||||||
| WidowX 250 | Trossen Robotics | Arm | yes | MJCF | |||||||||
| WSG 50 | SCHUNK | Gripper or end effector | yes | SDF | |||||||||
| xArm5 | UFACTORY | Arm | yes | Xacro | |||||||||
| xarm7 Gripper | UFACTORY | Gripper or end effector | yes | MJCF | |||||||||
| XLeRobot developer assembly kit | Vector Wang | Mobile manipulator | yes | $579 | |||||||||
| YuMi | ABB | Dual arm | yes | URDF | |||||||||
| A2 Ultra | AgiBot | Humanoid | no | 1.75 | 55 | ||||||||
| AgiBot X1 | AgibotTech | Humanoid | yes | ||||||||||
| Dex5-1 | Unitree | Hand | no | 20 | 1.1 | ||||||||
| Digit | Agility Robotics | Humanoid | yes | ||||||||||
| Figure 03 | Figure AI | Humanoid | no | 60 | 1.7 | ||||||||
| Go2-W | Unitree | Quadruped | no | 18 | URDF | ||||||||
| Jackal | Clearpath Robotics | Wheeled base | no | Xacro | |||||||||
| PM01 | EngineAI | Humanoid | no | 24 | 1.38 | ||||||||
| SE01 | EngineAI | Humanoid | no | 32 | 1.7 | ||||||||
| Shadow Dexterous Hand | Shadow Robot | Hand | no | 20 | Xacro | ||||||||
| Stanford Pupper | Stanford Student Robotics | Quadruped | yes | ||||||||||
| T800 | EngineAI | Humanoid | no | 29 | 1.73 | ||||||||
| CRX-10iA | FANUC | Arm | no | Xacro | |||||||||
| CRX-10iA/L | FANUC | Arm | no | Xacro | |||||||||
| CRX-20iA/L | FANUC | Arm | no | Xacro | |||||||||
| CRX-30iA | FANUC | Arm | no | Xacro | |||||||||
| Hand-E | Robotiq | Gripper or end effector | no | 7 | |||||||||
| MG400 | Dobot | Arm | no | URDF | |||||||||
| MOTOMAN HC10 | Yaskawa | Arm | no | Xacro | |||||||||
| myCobot Pro 600 | Elephant Robotics | Arm | no | URDF | |||||||||
| NEO | 1X Technologies | Humanoid | no | $20,000 | |||||||||
| PincherX 100 | Trossen Robotics | Arm | no | Xacro | |||||||||
| SA01 | EngineAI | Humanoid | no | 12 | |||||||||
| Stretch 4 | Hello Robot | Mobile manipulator | partial | URDF | |||||||||
| Atlas | Boston Dynamics | Humanoid | no | ||||||||||
| Ekso EVO | Ekso Bionics | exoskeleton | no | ||||||||||
| TIAGo Pro | PAL Robotics | Mobile manipulator | no |