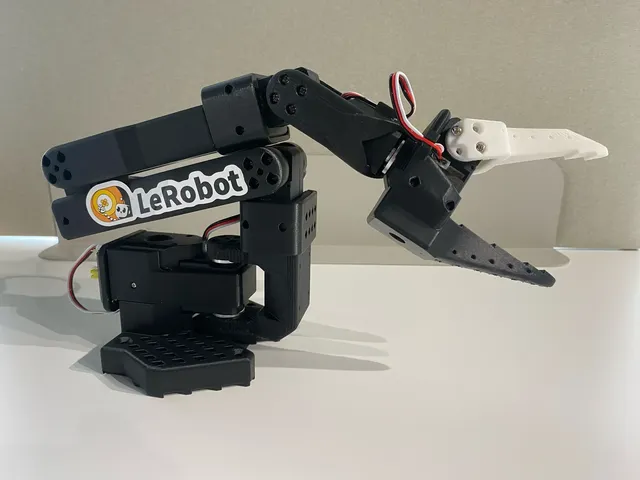
 Pixel-art render of the upstream model (MuJoCo Menagerie: robotstudio_so101/so101.xml, Apache-2.0). source · credits Photo: The Robot Studio (SO-ARM100 repository), Apache-2.0. source · credits

SO101
- Maker
- The Robot Studio
- Type
- Arm
- Open source
- yes
- Page
- https://github.com/google-deepmind/mujoco_menagerie/tree/main/robotstudio_so101
Worked example in the Design Book: the SO-101 arm
What is inside
From the published parts list. Counts add up the quantity column; a row with no quantity counts once.
 14Printed parts
 18Servos and actuators
 3Motor drivers
 2Wiring and connectors
 3Power
 4Tools and consumables
Parts list (28 rows)
Listed total: USD 351.82 (sum of rows with a price; not a quote)
| Kind | Item | Qty | Role | Material | Unit price | Vendor | Source |
|---|---|---|---|---|---|---|---|
 | STS3215 Servo 7.4V, 1/345 gear (C001) | 7 | joint actuator | USD 13.89 | Alibaba | raw.githubusercontent.com 2026-11-08 | |
| STS3215 Servo 7.4V, 1/191 gear (C044) | 2 | joint actuator | USD 13.89 | Alibaba | raw.githubusercontent.com 2026-11-08 | |
| STS3215 Servo 7.4V, 1/147 gear (C046) | 3 | joint actuator | USD 13.89 | Alibaba | raw.githubusercontent.com 2026-11-08 | |
 | Motor Control Board | 2 | motor driver or bus interface | USD 10.6 | Amazon | raw.githubusercontent.com 2026-11-08 | |
 | USB-C Cable 2 pcs | 1 | wiring | USD 7.0 | Amazon | raw.githubusercontent.com 2026-11-08 | |
 | Power Supply | 2 | power conversion | USD 10.0 | Amazon | raw.githubusercontent.com 2026-11-08 | |
 | Table Clamp 4pcs | 1 | tool or consumable | USD 9.0 | Amazon | raw.githubusercontent.com 2026-11-08 | |
| Screwdriver Set | 1 | tool (not part of the robot) | USD 6.0 | Amazon | raw.githubusercontent.com 2026-11-08 | |
| STS3215 Servo 7.4V, 1/345 gear (C001) | 6 | joint actuator | USD 13.89 | Alibaba | raw.githubusercontent.com 2026-11-08 | |
| Motor Control Board | 1 | motor driver or bus interface | USD 10.6 | Amazon | raw.githubusercontent.com 2026-11-08 | |
| USB-C Cable 2 pcs | 1 | wiring | USD 7.0 | Amazon | raw.githubusercontent.com 2026-11-08 | |
| Power Supply | 1 | power conversion | USD 10.0 | Amazon | raw.githubusercontent.com 2026-11-08 | |
| Table Clamp 2pcs | 1 | tool or consumable | USD 5.0 | Amazon | raw.githubusercontent.com 2026-11-08 | |
| Screwdriver Set | 1 | tool (not part of the robot) | USD 6.0 | Amazon | raw.githubusercontent.com 2026-11-08 | |
 | Base_motor_holder_SO101.stl | 1 | printed structure (leader and follower) | raw.githubusercontent.com 2026-11-08 | |||
| Base_SO101.stl | 1 | printed structure (leader and follower) | raw.githubusercontent.com 2026-11-08 | |||
| Motor_holder_SO101_Base.stl | 1 | printed structure (leader and follower) | raw.githubusercontent.com 2026-11-08 | |||
| Motor_holder_SO101_Wrist.stl | 1 | printed structure (leader and follower) | raw.githubusercontent.com 2026-11-08 | |||
| Under_arm_SO101.stl | 1 | printed structure (leader and follower) | raw.githubusercontent.com 2026-11-08 | |||
| Upper_arm_SO101.stl | 1 | printed structure (leader and follower) | raw.githubusercontent.com 2026-11-08 | |||
| Rotation_Pitch_SO101.stl | 1 | printed structure (leader and follower) | raw.githubusercontent.com 2026-11-08 | |||
| Wrist_Roll_Pitch_SO101.stl | 1 | printed structure (leader and follower) | raw.githubusercontent.com 2026-11-08 | |||
| WaveShare_Mounting_Plate_SO101.stl | 1 | printed structure (leader and follower) | raw.githubusercontent.com 2026-11-08 | |||
| Handle_SO101.stl | 1 | printed structure (leader) | raw.githubusercontent.com 2026-11-08 | |||
| Trigger_SO101.stl | 1 | printed structure (leader) | raw.githubusercontent.com 2026-11-08 | |||
| Wrist_Roll_SO101.stl | 1 | printed structure (leader) | raw.githubusercontent.com 2026-11-08 | |||
| Moving_Jaw_SO101.stl | 1 | printed structure (follower) | raw.githubusercontent.com 2026-11-08 | |||
| Wrist_Roll_Follower_SO101.stl | 1 | printed structure (follower) | raw.githubusercontent.com 2026-11-08 |
Specifications
| Attribute | Value | Conditions | Type | Source, read date, quote |
|---|---|---|---|---|
| Payload | 150 g | SO-ARM 101 column of Robonine's comparison table; stated by Robonine, not by The Robot Studio. | claim | raw.githubusercontent.com 2026-11-09“| Rated payload | 150 g | 300 g | |” |
| Reach | 441 mm | SO-ARM 101 column of Robonine's comparison table; stated by Robonine, not by The Robot Studio. | claim | raw.githubusercontent.com 2026-11-09“| Horizontal radius | 441 mm | 483 mm | +9.5 % |” |
Values from the upstream simulation model (13)
Joint limits, force limits and link masses in the model file. These are not maker datasheet values.
Show all 13
| Attribute | Value | Detail | Type | Source, read date, quote |
|---|---|---|---|---|
| Actuator force range elbow flex | -2.94 to 2.94 N·m | (robotstudio_so101/so101.xml), not a maker datasheet; actuator elbow_flex; forcerange set in default class | sim-model | raw.githubusercontent.com 2026-11-08“forcerange="-2.94 2.94"” |
| Actuator force range gripper | -2.94 to 2.94 N·m | (robotstudio_so101/so101.xml), not a maker datasheet; actuator gripper; forcerange set in default class | sim-model | raw.githubusercontent.com 2026-11-08“forcerange="-2.94 2.94"” |
| Actuator force range shoulder lift | -2.94 to 2.94 N·m | (robotstudio_so101/so101.xml), not a maker datasheet; actuator shoulder_lift; forcerange set in default class | sim-model | raw.githubusercontent.com 2026-11-08“forcerange="-2.94 2.94"” |
| Actuator force range shoulder pan | -2.94 to 2.94 N·m | (robotstudio_so101/so101.xml), not a maker datasheet; actuator shoulder_pan; forcerange set in default class | sim-model | raw.githubusercontent.com 2026-11-08“forcerange="-2.94 2.94"” |
| Actuator force range wrist flex | -2.94 to 2.94 N·m | (robotstudio_so101/so101.xml), not a maker datasheet; actuator wrist_flex; forcerange set in default class | sim-model | raw.githubusercontent.com 2026-11-08“forcerange="-2.94 2.94"” |
| Actuator force range wrist roll | -2.94 to 2.94 N·m | (robotstudio_so101/so101.xml), not a maker datasheet; actuator wrist_roll; forcerange set in default class | sim-model | raw.githubusercontent.com 2026-11-08“forcerange="-2.94 2.94"” |
| Joint range elbow flex | -1.69 to 1.69 rad | (robotstudio_so101/so101.xml), not a maker datasheet; joint elbow_flex | sim-model | raw.githubusercontent.com 2026-11-08“name="elbow_flex" type="hinge" range="-1.69 1.69"” |
| Joint range gripper | -0.174533 to 1.7453292 rad | (robotstudio_so101/so101.xml), not a maker datasheet; joint gripper | sim-model | raw.githubusercontent.com 2026-11-08“name="gripper" type="hinge" range="-0.174533 1.7453292"” |
| Joint range shoulder lift | -1.7453293 to 1.7453293 rad | (robotstudio_so101/so101.xml), not a maker datasheet; joint shoulder_lift | sim-model | raw.githubusercontent.com 2026-11-08“name="shoulder_lift" type="hinge" range="-1.7453293 1.7453293"” |
| Joint range shoulder pan | -1.91986 to 1.91986 rad | (robotstudio_so101/so101.xml), not a maker datasheet; joint shoulder_pan | sim-model | raw.githubusercontent.com 2026-11-08“name="shoulder_pan" type="hinge" range="-1.91986 1.91986"” |
| Joint range wrist flex | -1.658063 to 1.658063 rad | (robotstudio_so101/so101.xml), not a maker datasheet; joint wrist_flex | sim-model | raw.githubusercontent.com 2026-11-08“name="wrist_flex" type="hinge" range="-1.658063 1.658063"” |
| Joint range wrist roll | -2.7438473 to 2.8412063 rad | (robotstudio_so101/so101.xml), not a maker datasheet; joint wrist_roll | sim-model | raw.githubusercontent.com 2026-11-08“name="wrist_roll" type="hinge" range="-2.7438473 2.8412063"” |
| Link mass base | 0.147 kg | (robotstudio_so101/so101.xml), not a maker datasheet; body base | sim-model | raw.githubusercontent.com 2026-11-08“<body name="base" pos="0 0 0" quat="1 0 0 0" childclass="so101"> <inertial pos="0.0137179 -5.19711e-05 0.0334843" mass="0.147"” |
Simulation models
| Format | Library | Licence | File |
|---|---|---|---|
| MJCF | mujoco_menagerie | Apache-2.0 | robotstudio_so101 |
| URDF | robot_descriptions.py | Apache-2.0 | so_arm101_description |
| MJCF | robot_descriptions.py | Apache-2.0 | so_arm101_mj_description |
| MJCF | awesome-robot-descriptions | Apache-2.0 | https://github.com/google-deepmind/mujoco_menagerie/tree/main/robotstudio_so101 |