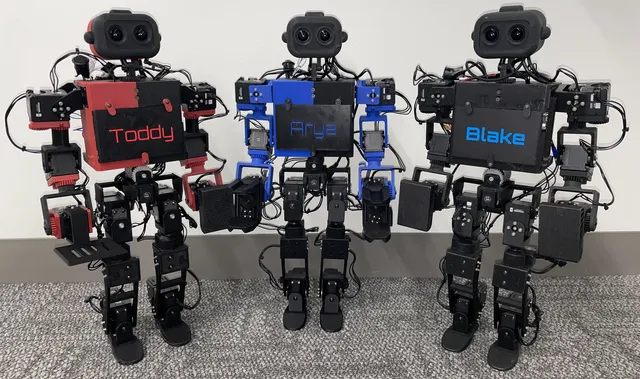
 Pixel-art render of the upstream model (MuJoCo Menagerie: toddlerbot_2xc/toddlerbot_2xc.xml, MIT). source · credits Photo: Haochen Shi (ToddlerBot project), MIT. source · credits

2XC
- Maker
- ToddlerBot
- Type
- Humanoid
- Open source
- yes
- Page
- https://github.com/google-deepmind/mujoco_menagerie/tree/main/toddlerbot_2xc
Worked example in the Design Book: an open humanoid, ToddlerBot 2XC
What is inside
From the published parts list. Counts add up the quantity column; a row with no quantity counts once.
 76Wiring and connectors
 117Electronics
 209Fasteners
 38Servos and actuators
 34Bearings
 3Bus adapters
 2Computers
 3Power
 2Batteries
 2Cameras
 1Sensors
 6Tools and consumables
Parts list (93 rows)
Listed total: USD 5,934.98 (sum of rows with a price; not a quote)
| Kind | Item | Qty | Role | Material | Unit price | Vendor | Source |
|---|---|---|---|---|---|---|---|
 | DYNAMIXEL 2XC430-W250-T | 2 | Motors | USD 298.89 | docs.google.com 2026-11-08 | ||
| DYNAMIXEL 2XL430-W250-T | 6 | Motors | USD 149.39 | docs.google.com 2026-11-08 | ||
| DYNAMIXEL XC330-T288-T | 6 | Motors | USD 103.39 | docs.google.com 2026-11-08 | ||
| DYNAMIXEL XC430-T240BB-T | 4 | Motors | USD 137.89 | docs.google.com 2026-11-08 | ||
| DYNAMIXEL XM430-W210-T | 4 | Motors | USD 310.39 | docs.google.com 2026-11-08 | ||
| DYNAMIXEL HN11-I101 Set | 10 | structure | USD 8.05 | docs.google.com 2026-11-08 | ||
| DYNAMIXEL HN12-I101 Set | 4 | structure | USD 20.47 | docs.google.com 2026-11-08 | ||
| DYNAMIXEL XC330-T288-T | 2 | joint actuator | USD 103.39 | docs.google.com 2026-11-08 | ||
 | Jetson Orin NX 16G | 1 | Computers | USD 955.0 | docs.google.com 2026-11-08 | ||
 | M.2 CB375NF Wifi Card | 1 | Computers | USD 18.36 | docs.google.com 2026-11-08 | ||
| WiFi Antenna | 1 | Computers | USD 9.49 | docs.google.com 2026-11-08 | ||
 | FIsheye Camera | 2 | Sensors | USD 49.99 | docs.google.com 2026-11-08 | ||
| Phone Speaker | 1 | user interface | USD 5.99 | www.amazon.com | docs.google.com 2026-11-08 | |
| Speaker Driver | 1 | user interface | USD 7.99 | docs.google.com 2026-11-08 | ||
 | BNO085 IMU | 1 | Sensors | USD 24.95 | docs.google.com 2026-11-08 | ||
 | M2*6 Pre-coated Screws | 200 | fastener | USD 0.01 | e.tb.cn | docs.google.com 2026-11-08 | |
| M2 Screw Kit | 2 | fastener | USD 8.99 | docs.google.com 2026-11-08 | ||
| M2.5 Screw Kit | 1 | fastener | USD 9.99 | docs.google.com 2026-11-08 | ||
| M3 Flat Head Screw Kit | 1 | fastener | USD 9.99 | docs.google.com 2026-11-08 | ||
| M3*8 Set Screw | 1 | fastener | USD 6.99 | docs.google.com 2026-11-08 | ||
| M3*10 Set Screw | 1 | fastener | USD 6.99 | docs.google.com 2026-11-08 | ||
| M4 Screw Kit | 1 | fastener | USD 22.38 | docs.google.com 2026-11-08 | ||
| M4 Long Screw Kit | 1 | fastener | USD 9.58 | docs.google.com 2026-11-08 | ||
| M3 and M4 Lock Nuts Kit | 1 | fastener | USD 7.98 | docs.google.com 2026-11-08 | ||
 | Vibra-TITE 213 Threadlocker | 1 | consumable | USD 6.55 | docs.google.com 2026-11-08 | ||
 | Bearing 683 10pcs | 1 | bearing | USD 11.96 | docs.google.com 2026-11-08 | ||
| Bearing 684 10pcs | 2 | bearing | USD 7.99 | docs.google.com 2026-11-08 | ||
| Bearing AXK0414 | 30 | bearing | USD 1.48 | docs.google.com 2026-11-08 | ||
| Bushing 3*5*5 10pcs | 1 | bearing | USD 5.99 | docs.google.com 2026-11-08 | ||
| 5mm Rubber Tape | 1 | consumable | USD 16.99 | www.amazon.com | docs.google.com 2026-11-08 | |
 | Step Down Power Converter 12V 4.5A | 2 | power supply | USD 34.95 | docs.google.com 2026-11-08 | ||
 | USB to Mirco USB Cable 0.5 Feet | 1 | wiring | USD 5.98 | www.amazon.com | docs.google.com 2026-11-08 | |
| USB to Mirco USB Cable 1.5 Feet | 1 | wiring | USD 8.99 | www.amazon.com | docs.google.com 2026-11-08 | |
| USB Hub Port Splitter | 1 | wiring | USD 6.98 | www.amazon.com | docs.google.com 2026-11-08 | |
| Jumper Wire | 1 | wiring | USD 6.98 | www.amazon.com | docs.google.com 2026-11-08 | |
| JST EH Cable | 10 | connector | USD 0.38 | www.digikey.com | docs.google.com 2026-11-08 | |
| JST EH Housing | 25 | connector | USD 0.05 | www.digikey.com | docs.google.com 2026-11-08 | |
| 5 Pairs of XT30 Male and Female Plugs | 1 | connector | USD 9.99 | www.amazon.com | docs.google.com 2026-11-08 | |
| XT30 to XT60 Male Female 4 pcs | 1 | connector | USD 8.99 | www.amazon.com | docs.google.com 2026-11-08 | |
| Barrel Jack Connector | 1 | connector | USD 9.49 | www.amazon.com | docs.google.com 2026-11-08 | |
| Rocker Switch 5 pcs | 1 | power distribution | USD 5.99 | www.amazon.com | docs.google.com 2026-11-08 | |
 | 2000 mAh Lipo Battery | 1 | battery | USD 49.99 | www.amazon.com | docs.google.com 2026-11-08 | |
| Lipo Battery Voltage Tester | 1 | tool (not part of the robot) | USD 12.95 | www.amazon.com | docs.google.com 2026-11-08 | |
| Lipo Battery Balance Charger | 1 | battery charger | USD 31.99 | www.amazon.com | docs.google.com 2026-11-08 | |
| 14 AWG Power Extension Cable | 1 | wiring | USD 17.49 | www.amazon.com | docs.google.com 2026-11-08 | |
| PLA-CF 1KG | 2 | consumable | PLA-CF 1KG | USD 34.99 | us.store.bambulab.com | docs.google.com 2026-11-08 |
| PLA 1KG | 1 | consumable | PLA 1KG | USD 19.99 | us.store.bambulab.com | docs.google.com 2026-11-08 |
 | MountingHole (MountingHole_3.2mm_M3) | 1 | PCB component | raw.githubusercontent.com 2026-11-08 | |||
| SpacerHole (MountingHole_3.2mm_M3) | 1 | PCB component | raw.githubusercontent.com 2026-11-08 | |||
| Conn_01x04 (PinSocket_1x04_P2.54mm_Vertical) | 1 | PCB component | LCSC | raw.githubusercontent.com 2026-11-08 | ||
| TTL Out5 (JST_EH_B3B-EH-A_1x03_P2.50mm_Vertical) | 1 | PCB component | LCSC | raw.githubusercontent.com 2026-11-08 | ||
| TTL Out6 (JST_EH_B3B-EH-A_1x03_P2.50mm_Vertical) | 1 | PCB component | LCSC | raw.githubusercontent.com 2026-11-08 | ||
| Switch Terminal (TerminalBlock_MetzConnect_Type011_RT05502HBWC_1x02_P5.00mm_Horizontal) | 1 | PCB component | LCSC | raw.githubusercontent.com 2026-11-08 | ||
| Conn_02x06_Buck2 (PinSocket_2x06_P2.54mm_Vertical) | 1 | PCB component | LCSC | raw.githubusercontent.com 2026-11-08 | ||
| Conn_02x06_Buck1 (PinSocket_2x06_P2.54mm_Vertical) | 1 | PCB component | LCSC | raw.githubusercontent.com 2026-11-08 | ||
| Power Out [Jetson] (AMASS_XT30UPB-F_1x02_P5.0mm_Vertical) | 1 | PCB component | LCSC | raw.githubusercontent.com 2026-11-08 | ||
| Power Out [Extra1] (AMASS_XT30UPB-F_1x02_P5.0mm_Vertical) | 1 | PCB component | LCSC | raw.githubusercontent.com 2026-11-08 | ||
| Power Out[Extra2] (AMASS_XT30UPB-F_1x02_P5.0mm_Vertical) | 1 | PCB component | LCSC | raw.githubusercontent.com 2026-11-08 | ||
| TTL Input Socket (JST_EH_B3B-EH-A_1x03_P2.50mm_Vertical) | 1 | PCB component | LCSC | raw.githubusercontent.com 2026-11-08 | ||
| TTL Out1 (JST_EH_B3B-EH-A_1x03_P2.50mm_Vertical) | 1 | PCB component | LCSC | raw.githubusercontent.com 2026-11-08 | ||
| TTL Out2 (JST_EH_B3B-EH-A_1x03_P2.50mm_Vertical) | 1 | PCB component | LCSC | raw.githubusercontent.com 2026-11-08 | ||
| TTL Out3 (JST_EH_B3B-EH-A_1x03_P2.50mm_Vertical) | 1 | PCB component | LCSC | raw.githubusercontent.com 2026-11-08 | ||
| TTL Out4 (JST_EH_B3B-EH-A_1x03_P2.50mm_Vertical) | 1 | PCB component | LCSC | raw.githubusercontent.com 2026-11-08 | ||
| 12V jumper (SolderJumper-2_P1.3mm_Open_RoundedPad1.0x1.5mm) | 1 | PCB component | raw.githubusercontent.com 2026-11-08 | |||
| XT30UPB-M (XT30UPB-M) | 1 | PCB component | LCSC | raw.githubusercontent.com 2026-11-08 | ||
| 100nF (0603) | 16 | PCB component | LCSC | raw.githubusercontent.com 2026-11-08 | ||
| 1uF (0603) | 1 | PCB component | LCSC | raw.githubusercontent.com 2026-11-08 | ||
| 22uF (0603) | 1 | PCB component | LCSC | raw.githubusercontent.com 2026-11-08 | ||
| 20pF (0603) | 2 | PCB component | LCSC | raw.githubusercontent.com 2026-11-08 | ||
| LEDG (0402) | 8 | PCB component | LCSC | raw.githubusercontent.com 2026-11-08 | ||
| LEDB (0402) | 8 | PCB component | LCSC | raw.githubusercontent.com 2026-11-08 | ||
| LED (0402) | 1 | PCB component | LCSC | raw.githubusercontent.com 2026-11-08 | ||
| SN74LVC2G241DCUR (SOP50P310X90-8N) | 8 | PCB component | LCSC | raw.githubusercontent.com 2026-11-08 | ||
| TLV75533PDBVR (SOT95P280X145-5N) | 1 | PCB component | LCSC | raw.githubusercontent.com 2026-11-08 | ||
| Conn_01x03 (JST_EH_B3B-EH-A_1x03_P2.50mm_Vertical) | 8 | PCB component | LCSC | raw.githubusercontent.com 2026-11-08 | ||
| Power Out [Jetson] (AMASS_XT30UPB-F_1x02_P5.0mm_Vertical) | 1 | PCB component | LCSC | raw.githubusercontent.com 2026-11-08 | ||
| Switch Terminal (TerminalBlock_MetzConnect_Type011_RT05502HBWC_1x02_P5.00mm_Horizontal) | 1 | PCB component | LCSC | raw.githubusercontent.com 2026-11-08 | ||
| FSR1 (PinSocket_1x02_P2.54mm_Vertical) | 1 | PCB component | LCSC | raw.githubusercontent.com 2026-11-08 | ||
| FSR2 (PinSocket_1x02_P2.54mm_Vertical) | 1 | PCB component | LCSC | raw.githubusercontent.com 2026-11-08 | ||
| Conn_02x06_Buck2 (PinSocket_2x06_P2.54mm_Vertical) | 1 | PCB component | LCSC | raw.githubusercontent.com 2026-11-08 | ||
| Power Out [Extra1] (AMASS_XT30UPB-F_1x02_P5.0mm_Vertical) | 1 | PCB component | LCSC | raw.githubusercontent.com 2026-11-08 | ||
| USB_C_Receptacle_USB2.0 (USB_C_Receptacle_G-Switch_GT-USB-7010ASV) | 1 | PCB component | LCSC | raw.githubusercontent.com 2026-11-08 | ||
| Power Out[Extra2] (AMASS_XT30UPB-F_1x02_P5.0mm_Vertical) | 1 | PCB component | LCSC | raw.githubusercontent.com 2026-11-08 | ||
| Conn_02x06_Buck1 (PinSocket_2x06_P2.54mm_Vertical) | 1 | PCB component | LCSC | raw.githubusercontent.com 2026-11-08 | ||
| 10K (0603) | 35 | PCB component | LCSC | raw.githubusercontent.com 2026-11-08 | ||
| 510 (0402) | 9 | PCB component | LCSC | raw.githubusercontent.com 2026-11-08 | ||
| 820 (0402) | 10 | PCB component | LCSC | raw.githubusercontent.com 2026-11-08 | ||
| 5.1K (0603) | 2 | PCB component | LCSC | raw.githubusercontent.com 2026-11-08 | ||
| 4K7 (0603) | 2 | PCB component | LCSC | raw.githubusercontent.com 2026-11-08 | ||
| TXB0104RUT (Texas_R-PUQFN-N12) | 8 | PCB component | LCSC | raw.githubusercontent.com 2026-11-08 | ||
| XT30UPB-M (XT30UPB-M) | 1 | PCB component | LCSC | raw.githubusercontent.com 2026-11-08 | ||
| CH348L (LQFP-100_14x14mm_P0.5mm) | 1 | PCB component | LCSC | raw.githubusercontent.com 2026-11-08 | ||
| 8MHz (Crystal_SMD_3225-4Pin_3.2x2.5mm) | 1 | PCB component | LCSC | raw.githubusercontent.com 2026-11-08 |
Values from the upstream simulation model (28)
Joint limits, force limits and link masses in the model file. These are not maker datasheet values.
Show all 28
| Attribute | Value | Detail | Type | Source, read date, quote |
|---|---|---|---|---|
| Joint range left ankle pitch | -1.8325957145940577 to 0.9599310885968697 rad | (toddlerbot_2xc/toddlerbot_2xc_mjx.xml), not a maker datasheet; joint left_ankle_pitch | sim-model | raw.githubusercontent.com 2026-11-08“name="left_ankle_pitch" range="-1.8325957145940577 0.9599310885968697"” |
| Joint range left ankle roll | -1.221730476395941 to 1.2217304763961203 rad | (toddlerbot_2xc/toddlerbot_2xc_mjx.xml), not a maker datasheet; joint left_ankle_roll | sim-model | raw.githubusercontent.com 2026-11-08“name="left_ankle_roll" range="-1.221730476395941 1.2217304763961203"” |
| Joint range left hip pitch | -2.356194490192345 to 1.8325957145940461 rad | (toddlerbot_2xc/toddlerbot_2xc_mjx.xml), not a maker datasheet; joint left_hip_pitch | sim-model | raw.githubusercontent.com 2026-11-08“name="left_hip_pitch" range="-2.356194490192345 1.8325957145940461"” |
| Joint range left hip roll | -0.785398163397538 to 1.5707963267948069 rad | (toddlerbot_2xc/toddlerbot_2xc_mjx.xml), not a maker datasheet; joint left_hip_roll | sim-model | raw.githubusercontent.com 2026-11-08“name="left_hip_roll" range="-0.785398163397538 1.5707963267948069"” |
| Joint range left hip yaw drive | -1.8325957145940461 to 1.8325957145940461 rad | (toddlerbot_2xc/toddlerbot_2xc_mjx.xml), not a maker datasheet; joint left_hip_yaw_drive | sim-model | raw.githubusercontent.com 2026-11-08“name="left_hip_yaw_drive" range="-1.8325957145940461 1.8325957145940461"” |
| Joint range left hip yaw driven | -1.5707963267948957 to 1.5707963267948974 rad | (toddlerbot_2xc/toddlerbot_2xc_mjx.xml), not a maker datasheet; joint left_hip_yaw_driven | sim-model | raw.githubusercontent.com 2026-11-08“name="left_hip_yaw_driven" range="-1.5707963267948957 1.5707963267948974"” |
| Joint range left knee | -2.0943951023931953 to 0 rad | (toddlerbot_2xc/toddlerbot_2xc_mjx.xml), not a maker datasheet; joint left_knee | sim-model | raw.githubusercontent.com 2026-11-08“name="left_knee" range="-2.0943951023931953 0"” |
| Joint range neck pitch | -0.6108652381980767 to 1.3962634015954023 rad | (toddlerbot_2xc/toddlerbot_2xc_mjx.xml), not a maker datasheet; joint neck_pitch | sim-model | raw.githubusercontent.com 2026-11-08“name="neck_pitch" range="-0.6108652381980767 1.3962634015954023"” |
| Joint range neck pitch act | -0.6108652381980207 to 1.3962634015954583 rad | (toddlerbot_2xc/toddlerbot_2xc_mjx.xml), not a maker datasheet; joint neck_pitch_act | sim-model | raw.githubusercontent.com 2026-11-08“name="neck_pitch_act" range="-0.6108652381980207 1.3962634015954583"” |
| Joint range neck pitch back | -12.206419459589227 to 12.926321769129117 rad | (toddlerbot_2xc/toddlerbot_2xc_mjx.xml), not a maker datasheet; joint neck_pitch_back | sim-model | raw.githubusercontent.com 2026-11-08“name="neck_pitch_back" range="-12.206419459589227 12.926321769129117"” |
| Joint range neck pitch front | -18.488883882036344 to 6.643857346682001 rad | (toddlerbot_2xc/toddlerbot_2xc_mjx.xml), not a maker datasheet; joint neck_pitch_front | sim-model | raw.githubusercontent.com 2026-11-08“name="neck_pitch_front" range="-18.488883882036344 6.643857346682001"” |
| Joint range neck yaw drive | -2.8797932657906435 to 2.8797932657906435 rad | (toddlerbot_2xc/toddlerbot_2xc_mjx.xml), not a maker datasheet; joint neck_yaw_drive | sim-model | raw.githubusercontent.com 2026-11-08“name="neck_yaw_drive" range="-2.8797932657906435 2.8797932657906435"” |
| Joint range neck yaw driven | -2.6179938779914944 to 2.6179938779914944 rad | (toddlerbot_2xc/toddlerbot_2xc_mjx.xml), not a maker datasheet; joint neck_yaw_driven | sim-model | raw.githubusercontent.com 2026-11-08“name="neck_yaw_driven" range="-2.6179938779914944 2.6179938779914944"” |
| Joint range right hip pitch | -1.8325957145940186 to 2.3561944901923724 rad | (toddlerbot_2xc/toddlerbot_2xc_mjx.xml), not a maker datasheet; joint right_hip_pitch | sim-model | raw.githubusercontent.com 2026-11-08“name="right_hip_pitch" range="-1.8325957145940186 2.3561944901923724"” |
| Joint range waist act 1 | -4.677482395344782 to 4.677482395344825 rad | (toddlerbot_2xc/toddlerbot_2xc_mjx.xml), not a maker datasheet; joint waist_act_1 | sim-model | raw.githubusercontent.com 2026-11-08“name="waist_act_1" range="-4.677482395344782 4.677482395344825"” |
| Joint range waist act 2 | -4.69883892561642 to 4.656125865073187 rad | (toddlerbot_2xc/toddlerbot_2xc_mjx.xml), not a maker datasheet; joint waist_act_2 | sim-model | raw.githubusercontent.com 2026-11-08“name="waist_act_2" range="-4.69883892561642 4.656125865073187"” |
| Joint range waist roll | -0.5235987755983006 to 0.523598775598297 rad | (toddlerbot_2xc/toddlerbot_2xc_mjx.xml), not a maker datasheet; joint waist_roll | sim-model | raw.githubusercontent.com 2026-11-08“name="waist_roll" range="-0.5235987755983006 0.523598775598297"” |
| Joint range waist yaw | -1.5707963267948895 to 1.5707963267949037 rad | (toddlerbot_2xc/toddlerbot_2xc_mjx.xml), not a maker datasheet; joint waist_yaw | sim-model | raw.githubusercontent.com 2026-11-08“name="waist_yaw" range="-1.5707963267948895 1.5707963267949037"” |
| Link mass head | 0.143321 kg | (toddlerbot_2xc/toddlerbot_2xc_mjx.xml), not a maker datasheet; body head | sim-model | raw.githubusercontent.com 2026-11-08“<body name="head" pos="0 0.004 0.015" quat="1 0 0 0"> <joint axis="0 1 0" name="neck_pitch" range="-0.6108652381980767 1.3962634015954023"/> <inertial pos="-0.0104852 0.00111009 0.0447856" mass="0.143321"” |
| Link mass neck pitch plate | 0.002 kg | (toddlerbot_2xc/toddlerbot_2xc_mjx.xml), not a maker datasheet; body neck_pitch_plate | sim-model | raw.githubusercontent.com 2026-11-08“<body name="neck_pitch_plate" pos="-0.027 -0.0025 0.0326157" quat="1 0 0 0"> <joint axis="0 -1 0" name="neck_pitch_act" range="-0.6108652381980207 1.3962634015954583" class="XC330"/> <inertial pos="0 -0.00282818 0" mass="0.002"” |
| Link mass neck rod | 0.00297389 kg | (toddlerbot_2xc/toddlerbot_2xc_mjx.xml), not a maker datasheet; body neck_rod | sim-model | raw.githubusercontent.com 2026-11-08“<body name="neck_rod" pos="0.00723736 -0.0055 0.0019674" quat="1 0 0 0"> <joint axis="0 -1 0" name="neck_pitch_front" range="-18.488883882036344 6.643857346682001"/> <inertial pos="0.01348121 -0.00159086 -0.01631763" mass="0.00297389"” |
| Link mass neck rod 2 | 0.00297389 kg | (toddlerbot_2xc/toddlerbot_2xc_mjx.xml), not a maker datasheet; body neck_rod_2 | sim-model | raw.githubusercontent.com 2026-11-08“<body name="neck_rod_2" pos="-0.00723736 -0.0055 -0.0019674" quat="1 0 0 0"> <joint axis="0 -1 0" name="neck_pitch_back" range="-12.206419459589227 12.926321769129117"/> <inertial pos="0.01348682 -0.00159086 -0.01630248" mass="0.00297389"” |
| Link mass neck yaw gear drive | 0.003 kg | (toddlerbot_2xc/toddlerbot_2xc_mjx.xml), not a maker datasheet; body neck_yaw_gear_drive | sim-model | raw.githubusercontent.com 2026-11-08“<body name="neck_yaw_gear_drive" pos="-0.0215079 0 0.119" quat="1 0 0 0"> <joint axis="0 0 -1" name="neck_yaw_drive" range="-2.8797932657906435 2.8797932657906435" class="XC330"/> <inertial pos="0 0 0.0033841" mass="0.003"” |
| Link mass neck yaw link | 0.006 kg | (toddlerbot_2xc/toddlerbot_2xc_mjx.xml), not a maker datasheet; body neck_yaw_link | sim-model | raw.githubusercontent.com 2026-11-08“<body name="neck_yaw_link" pos="-0.00050787 0 0.124" quat="1 0 0 0"> <joint name="neck_yaw_driven" range="-2.6179938779914944 2.6179938779914944"/> <inertial pos="-3.41e-06 0 0.00821562" mass="0.006"” |
| Link mass pelvis link | 0.1052 kg | (toddlerbot_2xc/toddlerbot_2xc_mjx.xml), not a maker datasheet; body pelvis_link | sim-model | raw.githubusercontent.com 2026-11-08“<body name="pelvis_link" pos="0.0230079 0 -0.014" quat="1 0 0 0"> <joint axis="1 0 0" name="waist_roll" range="-0.5235987755983006 0.523598775598297" damping="0.5" armature="0.002" frictionloss="0.03"/> <inertial pos="-0.0231545 0 -0.0260806" mass="0.1052"” |
| Link mass torso | 1.11503 kg | (toddlerbot_2xc/toddlerbot_2xc_mjx.xml), not a maker datasheet; body torso | sim-model | raw.githubusercontent.com 2026-11-08“<body name="torso" pos="0 0 0.315053" quat="1 0 0 0" childclass="toddlerbot"> <freejoint name="torso_freejoint"/> <inertial pos="-0.0185985 -0.00416082 0.0626827" mass="1.11503"” |
| Link mass waist gear drive | 0.002 kg | (toddlerbot_2xc/toddlerbot_2xc_mjx.xml), not a maker datasheet; body waist_gear_drive | sim-model | raw.githubusercontent.com 2026-11-08“<body name="waist_gear_drive" pos="-0.01275 0 -0.0196" quat="1 0 0 0"> <joint name="waist_act_1" range="-4.677482395344782 4.677482395344825" class="XC330"/> <inertial pos="0 0 0.00671824" mass="0.002"” |
| Link mass waist gears | 0.0371617 kg | (toddlerbot_2xc/toddlerbot_2xc_mjx.xml), not a maker datasheet; body waist_gears | sim-model | raw.githubusercontent.com 2026-11-08“<body name="waist_gears" pos="-0.0165079 0 -0.00248651" quat="1 0 0 0"> <joint name="waist_yaw" range="-1.5707963267948895 1.5707963267949037"/> <inertial pos="0 0 -0.0129916" mass="0.0371617"” |
Simulation models
| Format | Library | Licence | File |
|---|---|---|---|
| MJCF | mujoco_menagerie | MIT | toddlerbot_2xc |
| MJCF | robot_descriptions.py | MIT | toddlerbot_2xc_mj_description |
| MJCF | awesome-robot-descriptions | MIT | https://github.com/google-deepmind/mujoco_menagerie/tree/main/toddlerbot_2xc |
| URDF | awesome-robot-descriptions | MIT | https://github.com/hshi74/toddlerbot/blob/main/toddlerbot/descriptions/toddlerbot_2xc/toddlerbot_2xc.urdf |