| Actuator force range fl hx | -1000 to 1000 N·m | (boston_dynamics_spot/spot.xml), not a maker datasheet; actuator fl_hx; forcerange set in default class | sim-model | raw.githubusercontent.com 2026-11-08“forcerange="-1000 1000"” |
| Actuator force range fl hy | -1000 to 1000 N·m | (boston_dynamics_spot/spot.xml), not a maker datasheet; actuator fl_hy; forcerange set in default class | sim-model | raw.githubusercontent.com 2026-11-08“forcerange="-1000 1000"” |
| Actuator force range fl kn | -1000 to 1000 N·m | (boston_dynamics_spot/spot.xml), not a maker datasheet; actuator fl_kn; forcerange set in default class | sim-model | raw.githubusercontent.com 2026-11-08“forcerange="-1000 1000"” |
| Actuator force range fr hx | -1000 to 1000 N·m | (boston_dynamics_spot/spot.xml), not a maker datasheet; actuator fr_hx; forcerange set in default class | sim-model | raw.githubusercontent.com 2026-11-08“forcerange="-1000 1000"” |
| Actuator force range fr hy | -1000 to 1000 N·m | (boston_dynamics_spot/spot.xml), not a maker datasheet; actuator fr_hy; forcerange set in default class | sim-model | raw.githubusercontent.com 2026-11-08“forcerange="-1000 1000"” |
| Actuator force range fr kn | -1000 to 1000 N·m | (boston_dynamics_spot/spot.xml), not a maker datasheet; actuator fr_kn; forcerange set in default class | sim-model | raw.githubusercontent.com 2026-11-08“forcerange="-1000 1000"” |
| Actuator force range hl hx | -1000 to 1000 N·m | (boston_dynamics_spot/spot.xml), not a maker datasheet; actuator hl_hx; forcerange set in default class | sim-model | raw.githubusercontent.com 2026-11-08“forcerange="-1000 1000"” |
| Actuator force range hl hy | -1000 to 1000 N·m | (boston_dynamics_spot/spot.xml), not a maker datasheet; actuator hl_hy; forcerange set in default class | sim-model | raw.githubusercontent.com 2026-11-08“forcerange="-1000 1000"” |
| Actuator force range hl kn | -1000 to 1000 N·m | (boston_dynamics_spot/spot.xml), not a maker datasheet; actuator hl_kn; forcerange set in default class | sim-model | raw.githubusercontent.com 2026-11-08“forcerange="-1000 1000"” |
| Actuator force range hr hx | -1000 to 1000 N·m | (boston_dynamics_spot/spot.xml), not a maker datasheet; actuator hr_hx; forcerange set in default class | sim-model | raw.githubusercontent.com 2026-11-08“forcerange="-1000 1000"” |
| Joint range fl hx | -0.785398 to 0.785398 rad | (boston_dynamics_spot/spot.xml), not a maker datasheet; joint fl_hx | sim-model | raw.githubusercontent.com 2026-11-08“name="fl_hx" axis="1 0 0" range="-0.785398 0.785398"” |
| Joint range fl hy | -0.898845 to 2.29511 rad | (boston_dynamics_spot/spot.xml), not a maker datasheet; joint fl_hy | sim-model | raw.githubusercontent.com 2026-11-08“name="fl_hy" axis="0 1 0" range="-0.898845 2.29511"” |
| Joint range fl kn | -2.7929 to -0.254402 rad | (boston_dynamics_spot/spot.xml), not a maker datasheet; joint fl_kn | sim-model | raw.githubusercontent.com 2026-11-08“name="fl_kn" axis="0 1 0" range="-2.7929 -0.254402"” |
| Joint range fr hx | -0.785398 to 0.785398 rad | (boston_dynamics_spot/spot.xml), not a maker datasheet; joint fr_hx | sim-model | raw.githubusercontent.com 2026-11-08“name="fr_hx" axis="1 0 0" range="-0.785398 0.785398"” |
| Joint range fr hy | -0.898845 to 2.24363 rad | (boston_dynamics_spot/spot.xml), not a maker datasheet; joint fr_hy | sim-model | raw.githubusercontent.com 2026-11-08“name="fr_hy" axis="0 1 0" range="-0.898845 2.24363"” |
| Joint range fr kn | -2.7929 to -0.255648 rad | (boston_dynamics_spot/spot.xml), not a maker datasheet; joint fr_kn | sim-model | raw.githubusercontent.com 2026-11-08“name="fr_kn" axis="0 1 0" range="-2.7929 -0.255648"” |
| Joint range hl hx | -0.785398 to 0.785398 rad | (boston_dynamics_spot/spot.xml), not a maker datasheet; joint hl_hx | sim-model | raw.githubusercontent.com 2026-11-08“name="hl_hx" axis="1 0 0" range="-0.785398 0.785398"” |
| Joint range hl hy | -0.898845 to 2.29511 rad | (boston_dynamics_spot/spot.xml), not a maker datasheet; joint hl_hy | sim-model | raw.githubusercontent.com 2026-11-08“name="hl_hy" axis="0 1 0" range="-0.898845 2.29511"” |
| Joint range hl kn | -2.7929 to -0.247067 rad | (boston_dynamics_spot/spot.xml), not a maker datasheet; joint hl_kn | sim-model | raw.githubusercontent.com 2026-11-08“name="hl_kn" axis="0 1 0" range="-2.7929 -0.247067"” |
| Joint range hr hx | -0.785398 to 0.785398 rad | (boston_dynamics_spot/spot.xml), not a maker datasheet; joint hr_hx | sim-model | raw.githubusercontent.com 2026-11-08“name="hr_hx" axis="1 0 0" range="-0.785398 0.785398"” |
| Joint range hr hy | -0.898845 to 2.29511 rad | (boston_dynamics_spot/spot.xml), not a maker datasheet; joint hr_hy | sim-model | raw.githubusercontent.com 2026-11-08“name="hr_hy" axis="0 1 0" range="-0.898845 2.29511"” |
| Joint range hr kn | -2.7929 to -0.248282 rad | (boston_dynamics_spot/spot.xml), not a maker datasheet; joint hr_kn | sim-model | raw.githubusercontent.com 2026-11-08“name="hr_kn" axis="0 1 0" range="-2.7929 -0.248282"” |
| Link mass body | 32.86 kg | (boston_dynamics_spot/spot.xml), not a maker datasheet; body body | sim-model | raw.githubusercontent.com 2026-11-08“<body name="body" childclass="spot" pos="0 0 .75"> <freejoint name="freejoint"/> <inertial pos="0.0063944 -9.81216e-05 0.000911379" mass="32.86"” |
| Link mass fl hip | 1.68 kg | (boston_dynamics_spot/spot.xml), not a maker datasheet; body fl_hip | sim-model | raw.githubusercontent.com 2026-11-08“<body name="fl_hip" pos="0.29785 0.055 0"> <inertial pos="-0.00537435 0.0128418 9.87523e-05" quat="1 1 -1 1" mass="1.68"” |
| Link mass fl lleg | 0.35 kg | (boston_dynamics_spot/spot.xml), not a maker datasheet; body fl_lleg | sim-model | raw.githubusercontent.com 2026-11-08“<body name="fl_lleg" pos="0.025 0 -0.32"> <inertial pos="0.00225794 4.6076e-05 -0.180082" quat="1 0 0 1" mass="0.35"” |
| Link mass fl uleg | 2.34 kg | (boston_dynamics_spot/spot.xml), not a maker datasheet; body fl_uleg | sim-model | raw.githubusercontent.com 2026-11-08“<body name="fl_uleg" pos="0 0.1108 0"> <inertial pos="0.00514237 -0.00243237 -0.121009" mass="2.34"” |
| Link mass fr hip | 1.68 kg | (boston_dynamics_spot/spot.xml), not a maker datasheet; body fr_hip | sim-model | raw.githubusercontent.com 2026-11-08“<body name="fr_hip" pos="0.29785 -0.055 0"> <inertial pos="-0.00537435 -0.0128418 -9.87523e-05" quat="1 1 -1 1" mass="1.68"” |
| Link mass fr lleg | 0.35 kg | (boston_dynamics_spot/spot.xml), not a maker datasheet; body fr_lleg | sim-model | raw.githubusercontent.com 2026-11-08“<body name="fr_lleg" pos="0.025 0 -0.32"> <inertial pos="0.00225794 4.6076e-05 -0.180082" quat="1 0 0 1" mass="0.35"” |
| Link mass fr uleg | 2.34 kg | (boston_dynamics_spot/spot.xml), not a maker datasheet; body fr_uleg | sim-model | raw.githubusercontent.com 2026-11-08“<body name="fr_uleg" pos="0 -0.1108 0"> <inertial pos="0.00514237 0.00243237 -0.121009" mass="2.34"” |
| Link mass hl hip | 1.68 kg | (boston_dynamics_spot/spot.xml), not a maker datasheet; body hl_hip | sim-model | raw.githubusercontent.com 2026-11-08“<body name="hl_hip" pos="-0.29785 0.055 0"> <inertial pos="0.00537435 0.0128418 -9.87523e-05" quat="1 1 -1 1" mass="1.68"” |
| Link mass hl lleg | 0.35 kg | (boston_dynamics_spot/spot.xml), not a maker datasheet; body hl_lleg | sim-model | raw.githubusercontent.com 2026-11-08“<body name="hl_lleg" pos="0.025 0 -0.32"> <inertial pos="0.00225794 4.6076e-05 -0.180082" quat="1 0 0 1" mass="0.35"” |
| Link mass hl uleg | 2.34 kg | (boston_dynamics_spot/spot.xml), not a maker datasheet; body hl_uleg | sim-model | raw.githubusercontent.com 2026-11-08“<body name="hl_uleg" pos="0 0.1108 0"> <inertial pos="0.00514237 -0.00243237 -0.121009" mass="2.34"” |
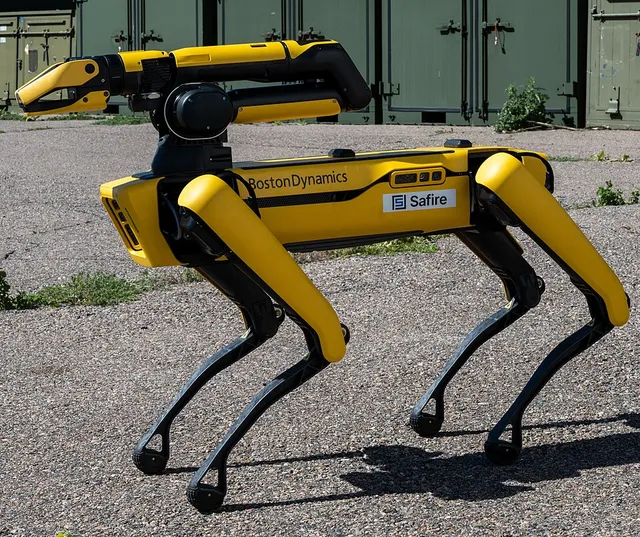 Pixel-art render of the upstream model (MuJoCo Menagerie: boston_dynamics_spot/spot.xml, BSD-3-Clause). source · credits Photo: Master Sgt. Amanda C. Geiger, Public domain. source · credits

