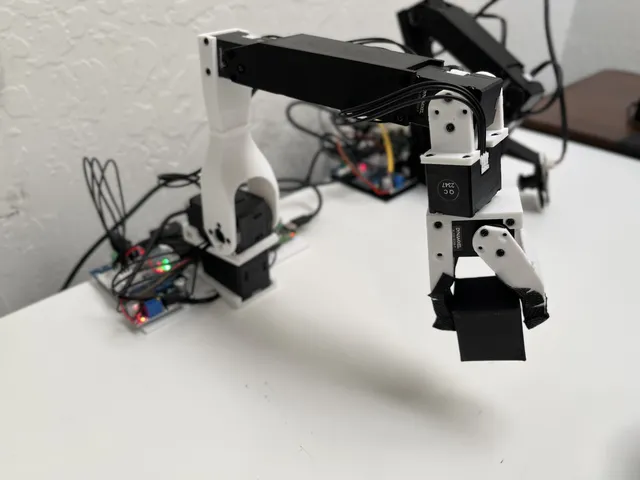
 Pixel-art render of the upstream model (MuJoCo Menagerie: low_cost_robot_arm/low_cost_robot_arm.xml, Apache-2.0). source · credits Photo: Alexander Koch, MIT. source · credits

Low-cost robot arm
- Maker
- Alexander Koch
- Type
- Arm
- Open source
- yes
- Page
- https://github.com/AlexanderKoch-Koch/low_cost_robot
What is inside
From the published parts list. Counts add up the quantity column; a row with no quantity counts once.
 15Servos and actuators
 3Power
 2Motor drivers
 1Wiring and connectors
 1Structure
 2Tools and consumables
Parts list (15 rows)
Listed total: USD 101.00 (sum of rows with a price; not a quote)
| Kind | Item | Qty | Role | Material | Unit price | Vendor | Source |
|---|---|---|---|---|---|---|---|
 | Dynamixel XL430-W250 | 2 | joint actuator | www.robotis.us | raw.githubusercontent.com 2026-11-08 | ||
| Dynamixel XL330-M288 | 4 | joint actuator | www.robotis.us | raw.githubusercontent.com 2026-11-08 | ||
| XL330 Idler Wheel | 1 | structure | USD 10.0 | www.robotis.us | raw.githubusercontent.com 2026-11-08 | |
| XL430 Idler Wheel | 1 | structure | USD 7.0 | www.robotis.us | raw.githubusercontent.com 2026-11-08 | |
 | Waveshare Serial Bus Servo Driver Board | 1 | motor driver or bus interface | USD 10.0 | a.co | raw.githubusercontent.com 2026-11-08 | |
 | Voltage Reducer | 1 | power supply | USD 10.0 | a.co | raw.githubusercontent.com 2026-11-08 | |
| 12V Power Supply | 1 | power conversion | USD 12.0 | a.co | raw.githubusercontent.com 2026-11-08 | |
 | Table Clamp | 1 | tool or consumable | USD 6.0 | a.co | raw.githubusercontent.com 2026-11-08 | |
 | Wires | 1 | wiring | USD 7.0 | a.co | raw.githubusercontent.com 2026-11-08 | |
| Dynamixel XL330-M077 | 6 | joint actuator | www.robotis.us | raw.githubusercontent.com 2026-11-08 | ||
 | XL330 Frame | 1 | structure | USD 7.0 | www.robotis.us | raw.githubusercontent.com 2026-11-08 | |
| XL330 Idler Wheel | 1 | structure | USD 10.0 | www.robotis.us | raw.githubusercontent.com 2026-11-08 | |
| Waveshare Serial Bus Servo Driver Board | 1 | motor driver or bus interface | USD 10.0 | a.co | raw.githubusercontent.com 2026-11-08 | |
| 5V Power Supply | 1 | power conversion | USD 6.0 | a.co | raw.githubusercontent.com 2026-11-08 | |
| Table Clamp | 1 | tool or consumable | USD 6.0 | a.co | raw.githubusercontent.com 2026-11-08 |
Values from the upstream simulation model (18)
Joint limits, force limits and link masses in the model file. These are not maker datasheet values.
Show all 18
| Attribute | Value | Detail | Type | Source, read date, quote |
|---|---|---|---|---|
| Actuator force range base rotation | -87 to 87 N·m | (low_cost_robot_arm/low_cost_robot_arm.xml), not a maker datasheet; actuator base_rotation | sim-model | raw.githubusercontent.com 2026-11-08“forcerange="-87 87"” |
| Actuator force range elbow | -87 to 87 N·m | (low_cost_robot_arm/low_cost_robot_arm.xml), not a maker datasheet; actuator elbow | sim-model | raw.githubusercontent.com 2026-11-08“forcerange="-87 87"” |
| Actuator force range gripper | -5 to 5 N·m | (low_cost_robot_arm/low_cost_robot_arm.xml), not a maker datasheet; actuator gripper | sim-model | raw.githubusercontent.com 2026-11-08“forcerange="-5 5"” |
| Actuator force range pitch | -87 to 87 N·m | (low_cost_robot_arm/low_cost_robot_arm.xml), not a maker datasheet; actuator pitch | sim-model | raw.githubusercontent.com 2026-11-08“forcerange="-87 87"” |
| Actuator force range wrist pitch | -12 to 12 N·m | (low_cost_robot_arm/low_cost_robot_arm.xml), not a maker datasheet; actuator wrist_pitch | sim-model | raw.githubusercontent.com 2026-11-08“forcerange="-12 12"” |
| Actuator force range wrist roll | -10 to 10 N·m | (low_cost_robot_arm/low_cost_robot_arm.xml), not a maker datasheet; actuator wrist_roll | sim-model | raw.githubusercontent.com 2026-11-08“forcerange="-10 10"” |
| Joint range base rotation | -2.2 to 2.2 rad | (low_cost_robot_arm/low_cost_robot_arm.xml), not a maker datasheet; joint base_rotation | sim-model | raw.githubusercontent.com 2026-11-08“name="base_rotation" pos="0 0 0" axis="0 0 -1" range="-2.2 2.2"” |
| Joint range elbow | -1.57 to 1.45 rad | (low_cost_robot_arm/low_cost_robot_arm.xml), not a maker datasheet; joint elbow | sim-model | raw.githubusercontent.com 2026-11-08“name="elbow" pos="0 0 0" axis="0 -1 0" range="-1.57 1.45"” |
| Joint range gripper | -1.6 to 0.032 rad | (low_cost_robot_arm/low_cost_robot_arm.xml), not a maker datasheet; joint gripper | sim-model | raw.githubusercontent.com 2026-11-08“name="gripper" pos="0 0 0" axis="0 0 -1" range="-1.60 0.032"” |
| Joint range pitch | -1.57 to 0.6 rad | (low_cost_robot_arm/low_cost_robot_arm.xml), not a maker datasheet; joint pitch | sim-model | raw.githubusercontent.com 2026-11-08“name="pitch" pos="0 0 0" axis="0 1 0" range="-1.57 0.6"” |
| Joint range wrist pitch | -2.0 to 2.0 rad | (low_cost_robot_arm/low_cost_robot_arm.xml), not a maker datasheet; joint wrist_pitch | sim-model | raw.githubusercontent.com 2026-11-08“name="wrist_pitch" pos="0 0 0" axis="0 1 0" range="-2.0 2.0"” |
| Joint range wrist roll | -3.14 to 3.14 rad | (low_cost_robot_arm/low_cost_robot_arm.xml), not a maker datasheet; joint wrist_roll | sim-model | raw.githubusercontent.com 2026-11-08“name="wrist_roll" pos="0 0 0" axis="1 0 0" range="-3.14 3.14"” |
| Link mass elbow to wrist | 0.019805 kg | (low_cost_robot_arm/low_cost_robot_arm.xml), not a maker datasheet; body elbow_to_wrist | sim-model | raw.githubusercontent.com 2026-11-08“<body name="elbow_to_wrist" pos="-0.10048 5e-05 0.0026999"> <inertial pos="-0.02652 0.019195 -9.0614e-06" quat="0.707361 0.706812 0.00580344 0.00484124" mass="0.019805"” |
| Link mass elbow to wrist extension | 0.06379 kg | (low_cost_robot_arm/low_cost_robot_arm.xml), not a maker datasheet; body elbow_to_wrist_extension | sim-model | raw.githubusercontent.com 2026-11-08“<body name="elbow_to_wrist_extension" pos="-0.0148 0.0065 0.1083"> <inertial pos="-0.05537 0.014505 0.0028659" quat="8.17663e-05 0.710999 -4.16983e-05 0.703193" mass="0.06379"” |
| Link mass gripper moving finger | 0.012831 kg | (low_cost_robot_arm/low_cost_robot_arm.xml), not a maker datasheet; body gripper_moving_finger | sim-model | raw.githubusercontent.com 2026-11-08“<body name="gripper_moving_finger" pos="-0.01315 -0.0075 0.0145"> <inertial pos="-0.02507 0.0010817 -0.01414" quat="0.528148 0.5474 0.466496 0.451436" mass="0.012831"” |
| Link mass gripper static finger | 0.029277 kg | (low_cost_robot_arm/low_cost_robot_arm.xml), not a maker datasheet; body gripper_static_finger | sim-model | raw.githubusercontent.com 2026-11-08“<body name="gripper_static_finger" pos="-0.045 0.013097 0"> <inertial pos="-0.019091 0.0053379 0.00018011" quat="0.105295 0.703509 -0.0986543 0.695885" mass="0.029277"” |
| Link mass shoulder rotation | 0.05014 kg | (low_cost_robot_arm/low_cost_robot_arm.xml), not a maker datasheet; body shoulder_rotation | sim-model | raw.githubusercontent.com 2026-11-08“<body name="shoulder_rotation" pos="0.012 0 0.0409"> <inertial pos="0.011924 -0.00048792 0.013381" quat="-0.0190903 0.705417 0.0178052 0.708312" mass="0.05014"” |
| Link mass shoulder to elbow | 0.050177 kg | (low_cost_robot_arm/low_cost_robot_arm.xml), not a maker datasheet; body shoulder_to_elbow | sim-model | raw.githubusercontent.com 2026-11-08“<body name="shoulder_to_elbow" pos="0 -0.0209 0.0154"> <inertial pos="0.0011747 0.02097 0.071547" quat="0.998768 2.01447e-05 0.0496266 0.000367169" mass="0.050177"” |
Simulation models
| Format | Library | Licence | File |
|---|---|---|---|
| MJCF | mujoco_menagerie | Apache-2.0 | low_cost_robot_arm |
| MJCF | robot_descriptions.py | Apache-2.0 | low_cost_robot_arm_mj_description |
| URDF | awesome-robot-descriptions | MIT | https://github.com/tc-huang/low_cost_robot/tree/6c42a82763c2ff056832b87314324b88faf51b61/ros2_ws/src/low_cost_robot_description |